Hyeonbeen LeeI am a first-year PhD student at Virginia Tech, where I'm working with Simon Stepputtis in the Thinking Embodied Agents (TEA) Lab. My research interests include Vision-Language-Action (VLA) models, contact-rich manipulation, real-time controller, and sensorless state estimation. Before joining Virginia Tech, I received my B.Eng. and M.Eng. degrees in Mechanical Engineering from Kyung Hee University, where I was advised by Jin-Gyun Kim in the Modeling & Simulation Lab. During my master's studies, I was also mentored by Hee-Sun Choi at Sejong University and Seongji Han at Chungnam National University. In 2023, I was fortunate to work with Joseph Lim in the CLVR Lab at KAIST. leehyeonbeen [at] vt.edu / CV / Scholar / ORCiD / GitHub |
|
ResearchI'm currently developing hierarchical Vision-Language-Action systems and sensorless contact perception methods for real-time robot controllers. Prior to joining Virginia Tech, I worked on data-driven modeling of contact- and vibration-rich physical dynamics at Kyung Hee University. |
|
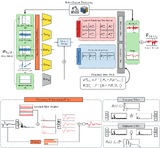
Frequency-aware decomposition learning for sensorless wrench estimation in vibration-rich robotic contactHyeonbeen Lee, Min-Jae Jung, Tae-Kyung Yeu, Jong-Boo Han, Daegil Park, Simon Stepputtis, Jin-Gyun Kim Submitted, 2026 [preprint] / [code] / [dataset] A novel decomposition-based framework enables sensorless, multi-step-ahead estimation of high-frequency contact wrench in robotic grinding. Pretraining on an open-source everyday manipulation dataset transfers low-frequency wrench dynamics to the downstream grinding setting. |
|
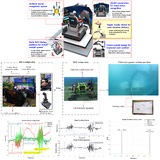
Buoyancy-integrated Hybrid Reaction Force Estimation Method with Real-time Haptic Feedback for Underwater Hydraulic ManipulationBonhak Koo, Min-Jae Jung, Hyeonbeen Lee, Tae-Kyung Yeu, Jin-Gyun Kim, Jong-Boo Han, Yeongjun Lee, Daegil Park Revised, 2026 A buoyancy-aware Kalman filter fuses hydraulic pressure- and DNN-based force estimates to enable sensorless, real-time haptic feedback in underwater environments. |
|
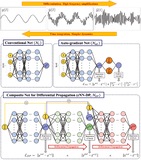
cNN-DP: Composite neural network with differential propagation for impulsive nonlinear dynamicsHyeonbeen Lee, Seongji Han, Hee-Sun Choi, Jin-Gyun Kim Journal of Computational Physics (JCR IF Top 2.5% in Physics, Mathematical), 2024 [paper] / [code] Progressively mapping from system parameters to higher-order dynamics via a chain of neural subnetworks, termed the differential propagation mechanism, enables accurate data-driven modeling of impulsive high-order nonlinear dynamics. |
|
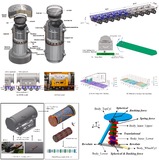
Multi-body dynamics model for spent nuclear fuel transportation system under normal transport test conditionsSeongji Han*, Gil-Eon Jeong*, Hyeonbeen Lee, Jin-Gyun Kim (* Co-first authors) Nuclear Engineering and Technology (JCR IF Top 13.7% in Nuclear Science & Technology), 2023 [paper] Simulates spent nuclear fuel transportation dynamics under normal road and sea conditions using a real-world-calibrated multi-body dynamics model. |
|
Design and source code from Jon Barron's website |